A journal of IEEE and CAA , publishes
high-quality papers in English on original
theoretical/experimental research
and development in all areas of automation
 Volume 13
Issue 9
IEEE/CAA Journal of Automatica Sinica
| Citation: | X. Jia, J. Zhang, B. Du, H. Yang, and U. A. Bhatti, “LSTM networks-based data-driven secure synchronization of interconnected systems with malicious subsystems,” IEEE/CAA J. Autom. Sinica, vol. 13, no. 9, pp. 2146–2162, Sep. 2026. doi: 10.1109/JAS.2026.125933

|

| [1] |
L. M. Pecora and T. L. Carroll, “Synchronization in chaotic systems,” Phys. Rev. Lett., vol. 64, no. 8, pp. 821−824, Feb. 1990. doi: 10.1103/PhysRevLett.64.821
|
| [2] |
M. Piekutowski, T. Litwinowicz, and R. J. Frowd, “Optimal short-term scheduling for a large-scale cascaded hydro system,” IEEE Trans. Power Syst., vol. 9, no. 2, pp. 805−811, May 1994. doi: 10.1109/59.317636
|
| [3] |
Y. Sun and N. H. El-Farra, “Resource aware quasi-decentralized control of networked process systems over wireless sensor networks,” Chem. Eng. Sci., vol. 69, no. 1, pp. 93−106, Feb. 2012. doi: 10.1016/j.ces.2011.10.010
|
| [4] |
Z. Zhao, T. Wang, J. Yu, and M. V. Basin, “Bilateral cooperative control of nonlinear multiagent systems with state and output quantification,” IEEE Trans. Cybern., vol. 55, no. 6, pp. 2949−2957, Jun. 2025. doi: 10.1109/TCYB.2025.3545144
|
| [5] |
H. Yang, Q. L. Han, X. Ge, L. Ding, Y. Xu, B. Jiang, and D. Zhou, “Fault-tolerant cooperative control of multiagent systems: A survey of trends and methodologies,” IEEE Trans. Ind. Inform., vol. 16, no. 1, pp. 4−17, Jan. 2020. doi: 10.1109/TII.2019.2945004
|
| [6] |
D. Ding, Q. L. Han, Y. Xiang, X. Ge, and X. Zhang, “A survey on security control and attack detection for industrial cyber-physical systems,” Neurocomputing, vol. 275, pp. 1674−1683, Jan. 2018. doi: 10.1016/j.neucom.2017.10.009
|
| [7] |
Z. Zhao, T. Wang, F. Peng, and J. Yu, “Adaptive fuzzy resilient decentralized control for nonlinear large-scale CPSs under DoS attacks,” IEEE Trans. Fuzzy Syst., vol. 32, no. 10, pp. 5899−5909, Oct. 2024. doi: 10.1109/TFUZZ.2024.3434726
|
| [8] |
S. Dhami, The Foundations of Behavioral Economic Analysis. New York, USA: Oxford University Press, 2016.
|
| [9] |
C. Zhang, H. Yang, B. Jiang, and M. Cao, “Flocking control against malicious agent,” IEEE Trans. Autom. Control, vol. 69, no. 5, pp. 3278−3285, May 2024. doi: 10.1109/TAC.2023.3319549
|
| [10] |
C. Shi and G. Yang, “Secure bearing-based target localization for multi-agent networks against malicious agents,” IEEE Trans. Autom. Sci. Eng., vol. 21, no. 4, pp. 5812−5825, Oct. 2024. doi: 10.1109/TASE.2023.3319334
|
| [11] |
S. Gil, C. Baykal, and D. Rus, “Resilient multi-agent consensus using Wi-Fi signals,” IEEE Control Syst. Lett., vol. 3, no. 1, pp. 126−131, Jan. 2019. doi: 10.1109/LCSYS.2018.2853641
|
| [12] |
F. Mallmann-Trenn, M. Cavorsi, and S. Gil, “Crowd vetting: Rejecting adversaries via collaboration with application to multirobot flocking,” IEEE Trans. Robot., vol. 38, no. 1, pp. 5−24, Feb. 2022. doi: 10.1109/TRO.2021.3089033
|
| [13] |
Y. Shang, “Consensus of hybrid multi-agent systems with malicious nodes,” IEEE Trans. Circuits Syst. II: Express Briefs, vol. 67, no. 4, pp. 685−689, Apr. 2020. doi: 10.1109/tcsii.2019.2918752
|
| [14] |
C. Zhao, J. He, and J. Chen, “Resilient consensus with mobile detectors against malicious attacks,” IEEE Trans. Signal Inform. Process. Over Networks, vol. 4, no. 1, pp. 60−69, Mar. 2018. doi: 10.1109/TSIPN.2017.2742859
|
| [15] |
X. Luo, C. Zhao, and J. He. “Secure multi-dimensional consensus algorithm against malicious attacks,” Automatica, vol. 157, Art. no. 111224, Nov. 2023.
|
| [16] |
H. Shen, Y. Wang, H. Yan, and S. Xu, “Data-driven single-loop policy iteration control of uncertain singularly perturbed systems,” IEEE Trans. Automat. Control, vol. 70, no. 12, pp. 8314−8320, Dec. 2025. doi: 10.1109/TAC.2025.3581141
|
| [17] |
H. Shen, C. Peng, H. Yan, and S. Xu, “Data-driven near optimization for fast sampling singularly perturbed systems,” IEEE Trans. Automat. Control, vol. 69, no. 7, pp. 4689−4694, Jul. 2024. doi: 10.1109/TAC.2024.3352703
|
| [18] |
Z. S. Hou and W. Zhuo, “From model-based control to data-driven control: Survey, classification and perspective,” Inform. Sci., vol. 235, pp. 3−35, Jun. 2013. doi: 10.1016/j.ins.2012.07.014
|
| [19] |
C. De Persis and P. Tesi, “Formulas for data-driven control: Stabilization, optimality, and robustness,” IEEE Trans. Autom. Control, vol. 65, no. 3, pp. 909−924, Mar. 2020. doi: 10.1109/TAC.2019.2959924
|
| [20] |
H. J. Van Waarde, J. Eising, M. K. Camlibel, and H. L. Trentelman, “The informativity approach: To data-driven analysis and control,” IEEE Control Syst. Mag., vol. 43, no. 6, pp. 32−66, Dec. 2023. doi: 10.1109/MCS.2023.3310305
|
| [21] |
X. Wang, J. Sun, G. Wang, F. Allgöwer, and J. Chen, “Data-driven control of distributed event-triggered network systems,” IEEE/CAA J. Autom. Sinica, vol. 10, no. 2, pp. 351−364, Feb. 2023. doi: 10.1109/JAS.2023.123225
|
| [22] |
S. Hu, D. Yue, Z. Jiang, X. Xie, and J. Zhang, “Data-driven security controller design for unknown networked systems,” Automatica, vol. 171, Art. no. 111843, Jan. 2025.
|
| [23] |
W. Liu, L. Li, J. Sun, F. Deng, G. Wang, and J. Chen, “Data-driven control against false data injection attacks,” Automatica, vol. 179, Art. no. 112399, Sep. 2025.
|
| [24] |
X. Wang, S. Zhao, X. Wang, M. Yang, and X. Wu, “Data-driven control for dynamic quantized nonlinear systems with state constraints based on barrier functions,” Inform. Sci., vol. 646, Art. no. 119132, Oct. 2023.
|
| [25] |
Y. Wang, T. Wang, C. Li, and J. Yang, “Neural network-based optimal fault-tolerant control for interconnected nonlinear systems with actuator failures,” IEEE Trans. Emerg. Top. Comput. Intell., vol. 8, no. 2, pp. 1828−1840, Apr. 2024. doi: 10.1109/TETCI.2024.3358981
|
| [26] |
X. Wang, D. Ding, X. Ge, and Q.-L. Han, “Supplementary control for quantized discrete-time nonlinear systems under goal representation heuristic dynamic programming,” IEEE Trans. Neural Netw. Learning Syst., vol. 35, no. 3, pp. 3202−3214, Mar. 2024. doi: 10.1109/TNNLS.2022.3201521
|
| [27] |
Y. Wang, R. Qi, and B. Jiang, “Distributed fault tolerant control of multi-agent system based on LSTM trajectory prediction model under intermittent communication faults,” J. Dyn. Syst., Meas., Control, vol. 147, no. 4, Art. no. 041005, Jul. 2025.
|
| [28] |
Y. Wang, J. Wang, J. Jiang, S. Xu, and J. Wang, “SA-LSTM: A trajectory prediction model for complex off-road multi-agent systems considering situation awareness based on risk field,” IEEE Trans. Veh. Technol., vol. 72, no. 11, pp. 14016−14027, Nov. 2023. doi: 10.1109/tvt.2023.3287227
|
| [29] |
J. Coulson, H. Van Waarde, and F. Dörfler, “Robust fundamental lemma for data-driven control,” arXiv preprint arXiv: 2205.06636, 2022.
|
| [30] |
X. Jia, J. Zhang, T. Raissi, W. Xing, and U. B. Bhatti, “Data-driven switched-gain observation and control,” Nonlinear Dyn., vol. 113, no. 14, pp. 17429−17447, Jul. 2025. doi: 10.1007/s11071-025-11133-z
|
| [31] |
V. P. Singh, N. Kishor, and P. Samuel, “Distributed multi-agent system-based load frequency control for multi-area power system in smart grid,” IEEE Trans. Ind. Electron., vol. 64, no. 6, pp. 5151−5160, Jun. 2017. doi: 10.1109/TIE.2017.2668983
|
| [32] |
D. Ding, Q.-L. Han, Z. Wang, and X. Ge, “A Survey on model-based distributed control and filtering for industrial cyber-physical systems,” IEEE Trans. Ind. Inform., vol. 15, no. 5, pp. 2483−2499, May 2019. doi: 10.1109/TII.2019.2905295
|
| [33] |
X. Duan, N. M. Freris, and P. Cheng, “Secure clock synchronization under collusion attacks,” in Proc. 54th Annu. Allerton Conf. Communication, Control, and Computing (Allerton), Monticello, USA, 2016, pp. 1142−1148.
|
| [34] |
T. M. Wolff, V. G. Lopez, and M. A. Müller, “Robust data-driven moving horizon estimation for linear discrete-time systems,” IEEE Trans. Autom. Control, vol. 69, no. 8, pp. 5598−5604, Aug. 2024. doi: 10.1109/TAC.2024.3371373
|
| [35] |
T. Graber, S. Lupberger, M. Unterreiner, and D. Schramm, “A hybrid approach to side-slip angle estimation with recurrent neural networks and kinematic vehicle models,” IEEE Trans. Intell. Veh., vol. 4, no. 1, pp. 39−47, Mar. 2019. doi: 10.1109/TIV.2018.2886687
|
| [36] |
H. Wang, H. Luo, Y. Jiang, and O. Kaynak, “Data-driven distributed diagnosis and optimization control for cascaded systems,” IEEE Trans. Syst., Man, Cybern.: Syst., vol. 54, no. 5, pp. 3001−3010, May 2024. doi: 10.1109/TSMC.2024.3352609
|
| [37] |
L. Cremean, W. B. Dunbar, D. Van Gogh, J. Hickey, E. Klavins, J. Meltzer, and R. M. Murray, “The Caltech multi-vehicle wireless testbed,” in Proc. 41st IEEE Conf. Decision and Control, Las Vegas, USA, 2002, pp. 86−88.
|
| [38] |
Z. Jin, S. Waydo, E. B. Wildanger, M. Lammers, H. Scholze, P. Foley, D. Held, and R. M. Murray, “MVWT-II: The second generation Caltech Multi-Vehicle Wireless Testbed,” in Proc. American Control Conf., Boston, USA, 2004, pp. 5321−5326.
|
| [39] |
B. Wang, “A distributed adaptive observer-based approach to synchronization of heterogeneous nonmonotonic nonlinear systems for formation application,” IEEE Trans. Automat. Control, vol. 69, no. 9, pp. 6137−6152, Sep. 2024. doi: 10.1109/TAC.2024.3392599
|
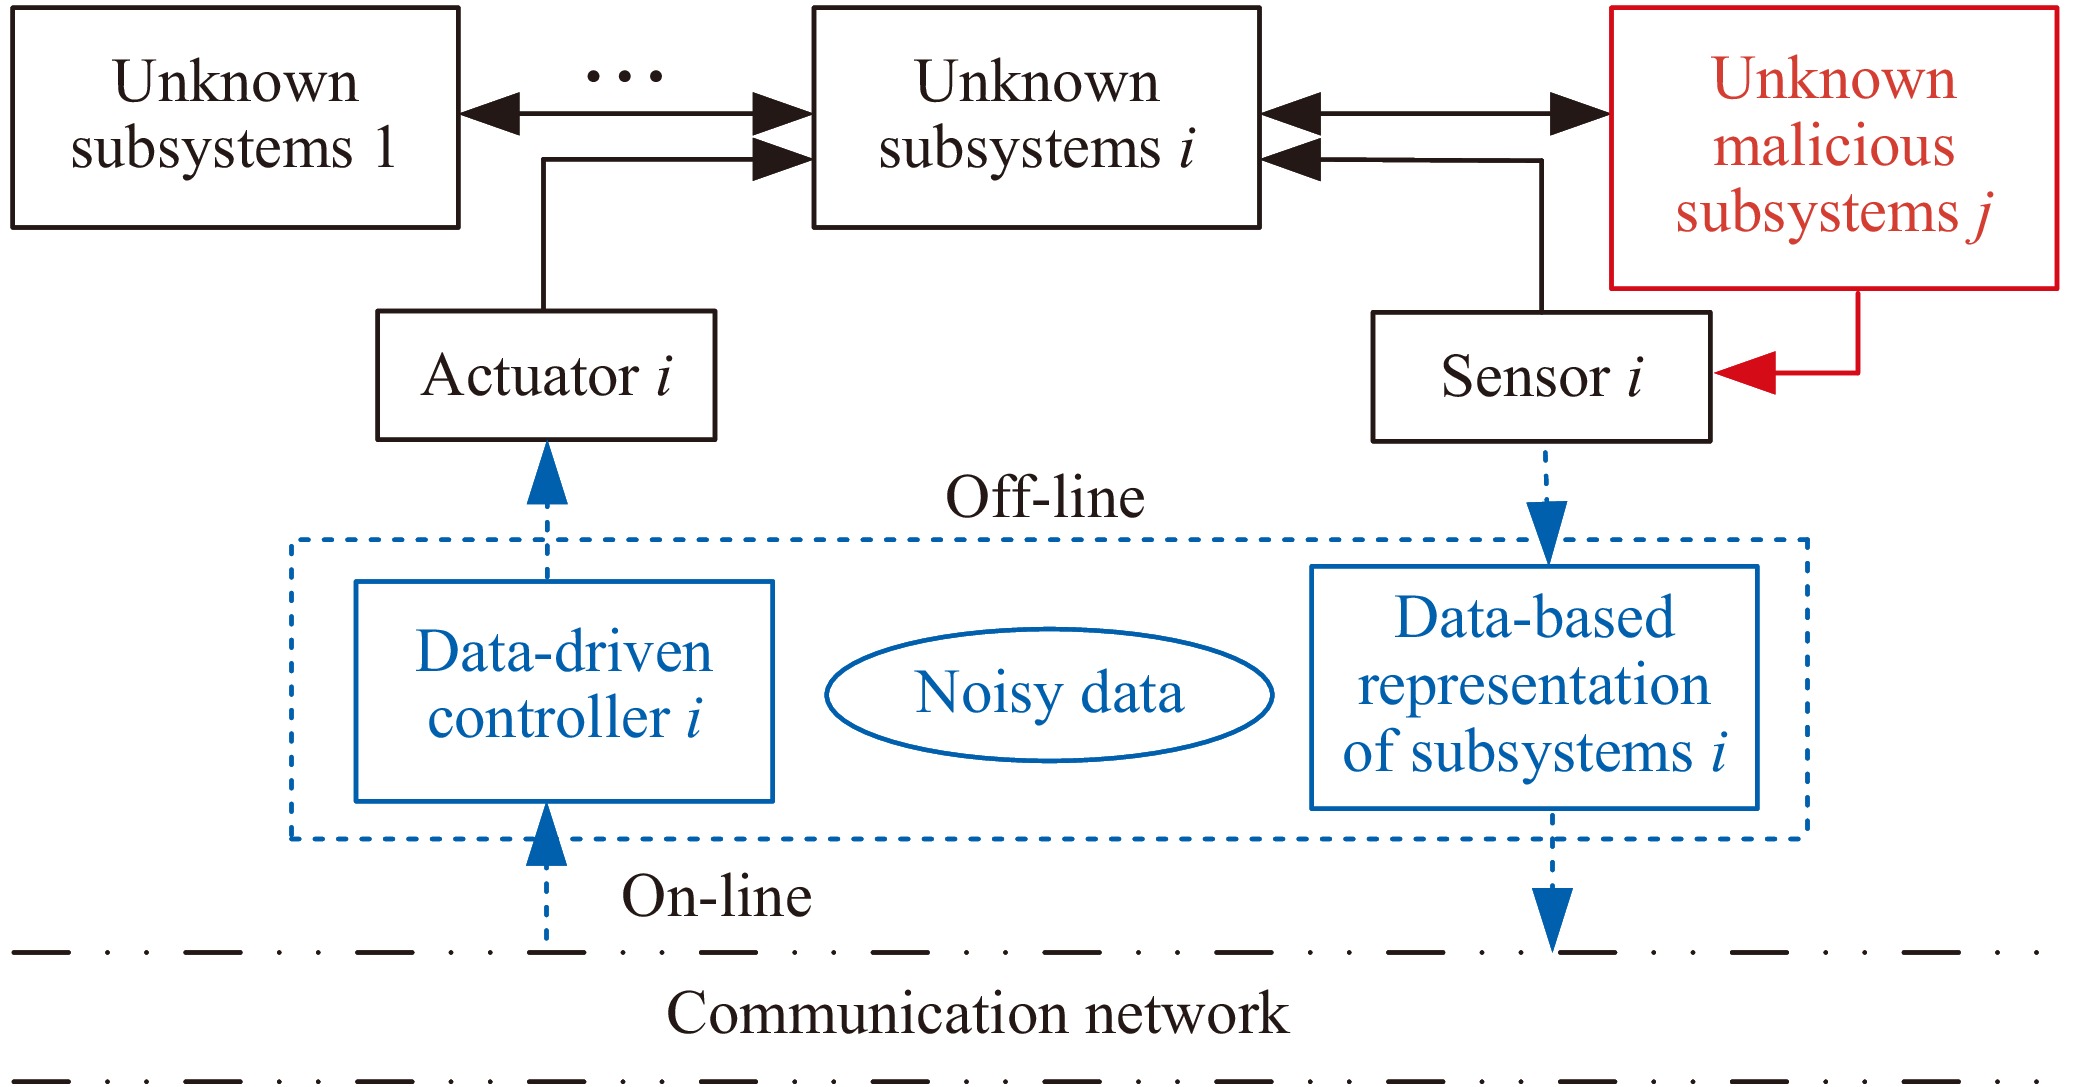
Figures(23) / Tables(3)




 DownLoad: