A journal of IEEE and CAA , publishes
high-quality papers in English on original
theoretical/experimental research
and development in all areas of automation
 Volume 13
Issue 9
IEEE/CAA Journal of Automatica Sinica
| Citation: | Z. Zhu, Y. Li, W. Yu, C. Chen, and X. Guan, “Depth information integrated pose graph optimization for multiple UUVs,” IEEE/CAA J. Autom. Sinica, vol. 13, no. 9, pp. 2169–2171, Sep. 2026. doi: 10.1109/JAS.2025.125654

|

| [1] |
W. Cao, J. Yan, X. Yang, X. Luo, and X. Guan, “Communication-aware formation control of AUVs with model uncertainty and fading channel via integral reinforcement learning,” IEEE/CAA J. Autom. Sinica, vol. 10, no. 1, pp. 159−176, Jan. 2023. doi: 10.1109/JAS.2023.123021
|
| [2] |
L. Jiang, Y. Li, W. Yu, and X. Guan, “Cooperative Localization for asynchronous AUVs using time difference of communication in underwater anchor-free environments,” IEEE Trans. Cybern., vol. 54, no. 11, pp. 6531−6544, Nov. 2024. doi: 10.1109/TCYB.2024.3447121
|
| [3] |
Y. Li, L. Liu, W. Yu, Y. Wang, and X. Guan, “Noncooperative mobile target tracking using multiple AUVs in anchor-free environments,” IEEE Internet Things J., vol. 7, no. 10, pp. 9819−9833, Oct. 2020. doi: 10.1109/JIOT.2020.2988307
|
| [4] |
J. Yan, L. Zhang, X. Yang, C. Chen, and X. Guan, “Communication-aware motion planning of AUV in obstacle-dense environment: A binocular vision-based deep learning method,” IEEE Trans. Intell. Transp. Syst., vol. 24, no. 12, pp. 14927−14943, Dec. 2023. doi: 10.1109/TITS.2023.3296415
|
| [5] |
D. Sapienza, E. Govi, S. Aldhaheri et al., “Model-based underwater 6D pose estimation from RGB,” IEEE Robot. Autom. Lett., vol. 8, no. 11, pp. 7535−7542, Nov. 2023. doi: 10.1109/LRA.2023.3320028
|
| [6] |
J. Tang, Z. Chen, B. Fu et al., “ROV6D: 6D pose estimation benchmark dataset for underwater remotely operated vehicles,” IEEE Robot. Autom. Lett., vol. 9, no. 1, pp. 65−72, Jan. 2024. doi: 10.1109/LRA.2023.3331624
|
| [7] |
B. Joshi, M. Modasshir, T. Manderson et al., “DeepURL: Deep pose estimation framework for underwater relative localization,” in Proc. IEEE/RSJ Int. Conf. Intell. Robots Syst., Las Vegas, NV, USA, 2020, pp. 1777−1784.
|
| [8] |
K. Harsányi, A. Kiss, T. Szirányi, and A. Majdik, “MASAT: A fast and robust algorithm for pose-graph initialization,” Pattern Recognit. Lett., vol. 129, pp. 131−136, Jan. 2020.
|
| [9] |
G. Hu, K. Khosoussi, and S. Huang, “Towards a reliable SLAM back-end,” in Proc. IEEE/RSJ Int. Conf. Intell. Robots Syst., Tokyo, Japan, 2013, pp. 37−43.
|
| [10] |
R. Kümmerle, G. Grisetti, H. Strasdat, K. Konolige, and W. Burgard, “G2o: A general framework for graph optimization,” in Proc. IEEE Int. Conf. Robot. Automat., Shanghai, China, 2011, pp. 3607−3613.
|
| [11] |
Y. Li, W. Yu, and X. Guan, “3D localization for multiple AUVs in anchor-free environments by exploring the use of depth information,” IEEE/CAA J. Autom. Sinica, vol. 11, no. 4, pp. 1051−1053, Apr. 2024. doi: 10.1109/JAS.2023.123261
|
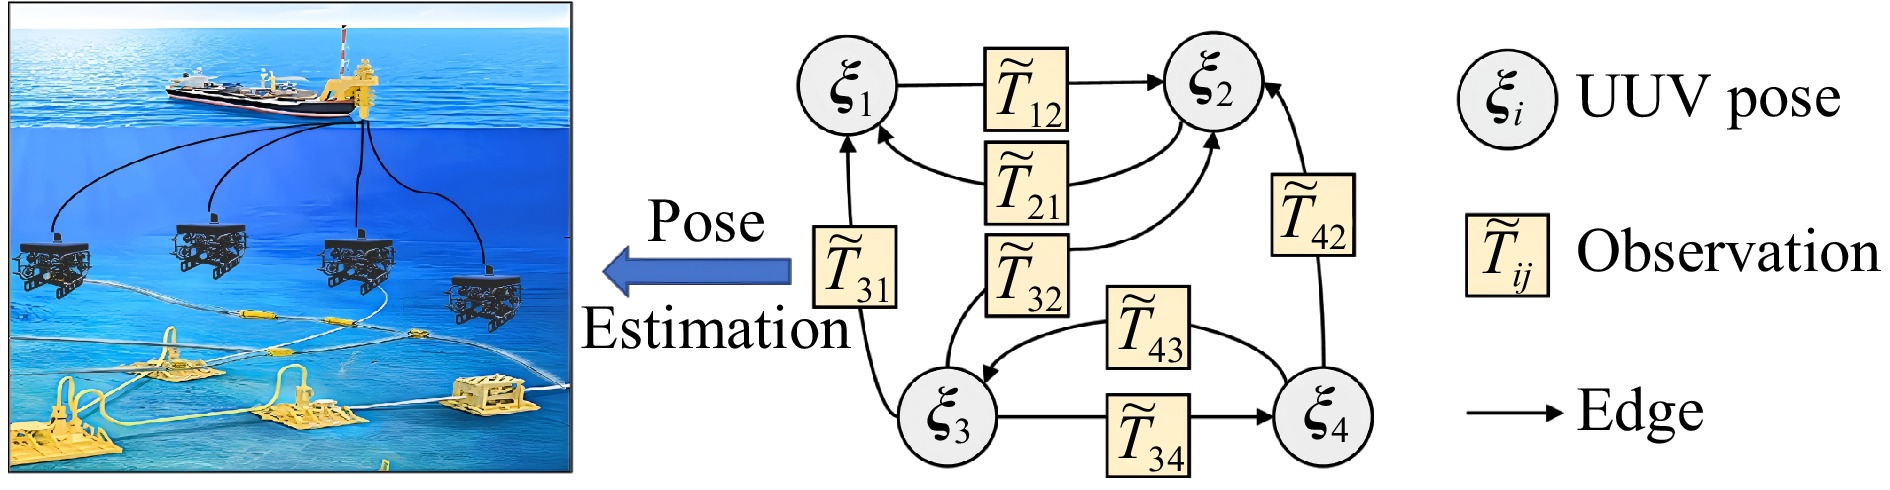
Figures(3) / Tables(1)




 DownLoad: